Week 18: Integration.
A.k.a. the final stretch: finishing Sandy 🎭✨
🪛 Overview
This week was about completing the final project and tracking progress along the way.
My final project is Sandy: The Performer, a string puppet moved by 7 servos and controlled from a phone over Wi-Fi. I presented it on 10 June 2026 🎤 Full documentation is on my Final Project page.
🎬 Final Presentation
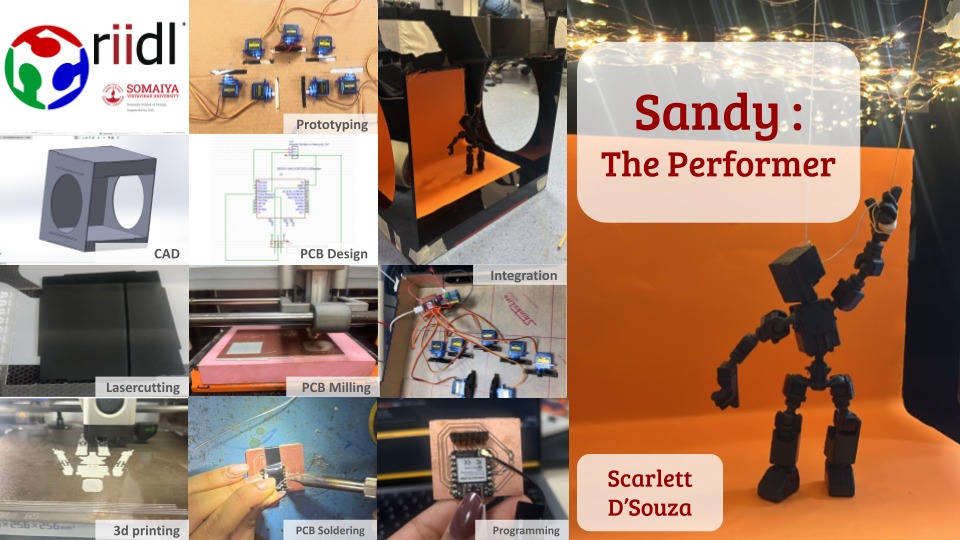
📅 Progress Tracker: 20 May → 10 June
Three weeks from "puppet on strings" to "puppet on stage". Dates without a ~ match the dates on my project files. ~ means approximate.
🔹 Before the tracker
- • 6 May: final project idea documented on my site
- • 8 May: first servo tests
- • 13 May: two servos running from the ESP32
🔹 Week 1 · 20–26 May: Prototype the motion
| Date | Task |
|---|---|
| ~20 May | Dropped the sound-reactive version (it felt random) and switched to voice + button control so Sandy can perform |
| 21 May | 3D printed the articulated puppet model from GrabCAD |
| ~22–25 May | Hand-puppeteered with strings on two dowel sticks to find the movement range and number of strings |
| 26 May | Single-servo test on the XIAO ESP32-S3, then swapped my hands for servos. It worked! |
🔹 Week 2 · 27 May – 2 June: Electronics + code
| Date | Task |
|---|---|
| ~27–28 May | Mapped all 7 servos on cardboard: head, 2 elbows, 2 wrists, 2 knees |
| ~29–30 May | Wired the PCA9685 driver over I²C and set the limp / neutral / pulled angles |
| ~31 May – 2 June | Firmware: Wi-Fi access point, WebSocket server, command parser, smooth motion, poses |
| ~2 June | Browser interface with voice input + quick command buttons |
🔹 Week 3 · 3–9 June: Fabrication + PCB
| Date | Task |
|---|---|
| ~3–6 June | Modelled the theatre in SolidWorks with slot joints, then laser cut it |
| ~6–7 June | Sanding + finishing the puppet |
| 8 June | Designed + 3D printed the SG90 pulleys that wind the strings |
| 9 June | Designed the XIAO PCB in EasyEDA, exported Gerbers, milled it |
| ~9 June | PCB #1 came out mirrored 🪞 and PCB #2 lost a trace. Also debugged Wi-Fi for hours (the antenna wasn't plugged in) (ಥ﹏ಥ) |
🔹 Presentation day · 10 June
| Date | Task |
|---|---|
| 10 June (2 am 🌙) | Final schematic saved |
| 10 June | Final assembly: puppet strung up in the theatre, fairy lights on |
| 10 June | Presentation slide + video made and uploaded |
| 10 June | Final presentation 🎤 |
✅ Completing the Final Project
🔹 What's done
- • Puppet with 7 string-driven joints, controlled by voice + buttons over Wi-Fi
- • Smooth servo motion using the limp / neutral / pulled system
- • Poses: stand, limp, wave, bow, dance, hands up
- • Custom XIAO ESP32-S3 PCB, laser-cut theatre, 3D-printed puppet + pulleys
- • Documentation, design files, presentation slide + video
🔹 What's still on the list
- • Hide the electronics inside the stage
- • Make string tension easier to re-tune (right now it drifts)
- • The autonomous "possessed" mode from my original idea 👀
- • The puppeteer hand that moves out of sync with the puppet
✨ What I Learned
- • Tracking progress week by week made it obvious when something was slipping
- • Leave buffer time before the deadline, because PCBs will come out mirrored 🪞
- • Documenting as I go is so much easier than reconstructing it all later