12. Mechanical Design, Machine Design
This week Hero shot!

This week Checklist
Group assignment
- [✓] Design a machine that includes mechanism + actuation + automation.
- [✓] Build the mechanical parts and operate it manually.
- [✓] Document our work.
Individual assignment
- [✓] Document my individual contribution.
Group assignment
This two weeks, our group try to design a robot arm that includes mechanism + actuation + automation. Please click here to see more details of our group assignment.
My individual contribution
▼ The first draft of project, it is a 4 DOF robot arm and additional 1 DOF for replaceable head for different usage.


▼ Use Fusion 360 to design and simulate robot arm action.

▼ Use my PCB board to control the robot arm.
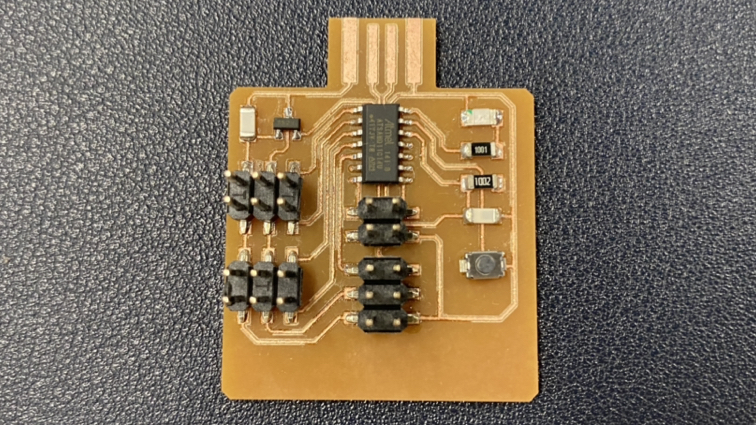
▼ Before assembly, component test is very important procedure.

▼ Adopt hidden wire design, most of the wires will not be exposed.


▼ The pin of axis 5 is located at the end of the robot arm, which is convenient to replace different heads.


▼ This is robot arm with spoon holder.

▼ This is clamp for robot arm.

▼ At present, three heads for different purposes have been designed for this robotic arm.

Coding
I want to make the robot arm action smoother, I wrote a subprogram of runServoPrg, which can divide the posts in the action into many parts and execute them one by one.
// System value
// ----------------------------------------------------------------------------------------------------

const int numberOfServos = 5; // Number of servos
const int numberOfACE = 6; // Number of action code elements
int servoCal[] = { 0, 0, 0, 0, 0, }; // Servo calibration data
int servoCurrentPos[] = { 0, 0, 0, 0, 0, }; // Servo current position
int servoOldPos[] = { 0, 0, 0, 0, 0, }; // Servo old position
int servoPrgPeriod = 20; // 20 ms
int servoPin[] = {5, 8, 9, 14, 15 }; // Initializing servo pin ( head to base )
int runProgram = false; // Flag for run program

const int buttonPin = 2; // The number of the pushbutton pin
int buttonState = 0; // Variable for reading the pushbutton status
const int ledPin = 4; // The number of the LED pin

// ----------------------------------------------------------------------------------------------------


// Action code
// ----------------------------------------------------------------------------------------------------

// Zero
int servoPrg00step = 1;
int servoPrg00 [][numberOfACE] PROGMEM = {
  // P05, P08, P09, P14, P15, ms
  {   90,  90,  90,  90,  90, 1000  }, // zero position
};

// Bread
int servoPrg01step = 12;
int servoPrg01 [][numberOfACE] PROGMEM = {
  // P05, P08, P09, P14, P15, ms
  {   90,  90,  90,  90,  40, 1000  }, // 轉向白碗
  {   90,  70,  10,  70,  40, 1000  }, // 放下機械臂
  {   70,  70,  15,  80,  45, 1000  }, // 放下湯匙
  {   80,  75,  10,  60,  45, 1000  }, // 升起湯匙
  {   85,  60,  10,  70, 110, 1000  }, // 轉向黃碗
  {   30, 100,  75, 100, 120, 1000  }, // 倒糖漿
  {   50, 100, 115, 140, 125, 1000  }, // 移到面包左上角
  {   50, 100, 100, 130, 140, 1000  }, // 移到面包左下角
  {   50, 100,  10,  30, 115, 1000  }, // 移到面包右下角
  {   50, 100,  50,  90, 100, 1000  }, // 移到面包右上角
  {   85,  60,  10,  70, 110, 1000  }, // 轉向黃碗
  {   90,  70,  10,  70,  40, 1000  }, // 轉向白碗放下機械臂
};

// ----------------------------------------------------------------------------------------------------


// Setup
// ----------------------------------------------------------------------------------------------------

void setup() {
  // Declaring servo pin as an output mode
  for(int s = 0; s < 5; s++){
    pinMode(servoPin[s], OUTPUT);
  }

  pinMode(buttonPin, INPUT); // Initialize the pushbutton pin as an input mode
  pinMode(ledPin, OUTPUT); // Initialize the LED pin as an output mode

  servoPos(90, 90, 90, 90, 90);
  runServoPrg(servoPrg00, servoPrg00step); // zero position
}

// ----------------------------------------------------------------------------------------------------


// Loop
// ----------------------------------------------------------------------------------------------------

void loop () {
  buttonState = digitalRead(buttonPin); // read the state of the pushbutton value

  // check if the pushbutton is pressed
  if (buttonState == LOW) {
    digitalWrite(ledPin, HIGH);
    runServoPrg(servoPrg01, servoPrg01step); // bread action
  } else {
    digitalWrite(ledPin, LOW);
  }

  delay(100);
}

// ----------------------------------------------------------------------------------------------------


// Function
// ----------------------------------------------------------------------------------------------------

void servoPos(int a1, int a2, int a3, int a4, int a5) {
  servoPulse(servoPin[0], a1);
  servoPulse(servoPin[1], a2);
  servoPulse(servoPin[2], a3);
  servoPulse(servoPin[3], a4);
  servoPulse(servoPin[4], a5);
  servoOldPos[0] = a1;
  servoOldPos[1] = a2;
  servoOldPos[2] = a3;
  servoOldPos[3] = a4;
  servoOldPos[4] = a5;
  delay(400);
}

void servoPulse (int servo, int angle) {
  int pwm = (angle*11) + 500; // Convert angle to microseconds
  digitalWrite(servo, HIGH);
  delayMicroseconds(pwm);
  digitalWrite(servo, LOW);
}

void runServoPrg(int servoPrg[][numberOfACE], int step)
{
  for (int i = 0; i < step; i++) { // Loop for step

    int totalTime = servoPrg[i][numberOfACE - 1]; // Total time of this step

    // Get servo start position
    for (int s = 0; s < numberOfServos; s++) {
      servoCurrentPos[s] = servoOldPos[s] - servoCal[s];
    }

    for (int j = 0; j < totalTime / servoPrgPeriod; j++) { // Loop for time section
      for (int k = 0; k < numberOfServos; k++) { // Loop for servo
        servoPulse(servoPin[k], (map(j, 0, totalTime / servoPrgPeriod, servoCurrentPos[k], servoPrg[i][k])) + servoCal[k]);
        servoOldPos[k] = (map(j, 0, totalTime / servoPrgPeriod, servoCurrentPos[k], servoPrg[i][k])) + servoCal[k];
      }
      delay(servoPrgPeriod);
    }
  }
}

// ----------------------------------------------------------------------------------------------------
Downloads
Robot Arm Fusion 360 Project f3d file
Robot Arm Code ino file