18. Applications and Implications, Project Development
So for this week I defined and planned what I will do for my final project week What does it do? - It can pick up and lift things using its steppers and the stepper. Also it is controlled through another device.
What sources did you use? - Youtube and Reddit mostly sometimes stack because I need code advice. I will include bellow the things i have used as who’s done what beforehand since they were my sources.
Who’s done what beforehand? - Before starting my own design, I looked at a few older Fab Academy and DIY robotic arm projects to see how other people built theirs. I looked at the:
Autonomous and Intelligent Robotic Arm by Cristiano Lemes from Fab Academy 2021
I also checked the FAB Arm from Fab Lab Trivandrum in 2017
I looked at the Affordable 5-DOF DIY Robot Arm guide on Element14
Out of youtube tutorials a lot of stuff has motivated me, speicifically the ones on cyclodal actuator design out of the ones i liked were but not limited to
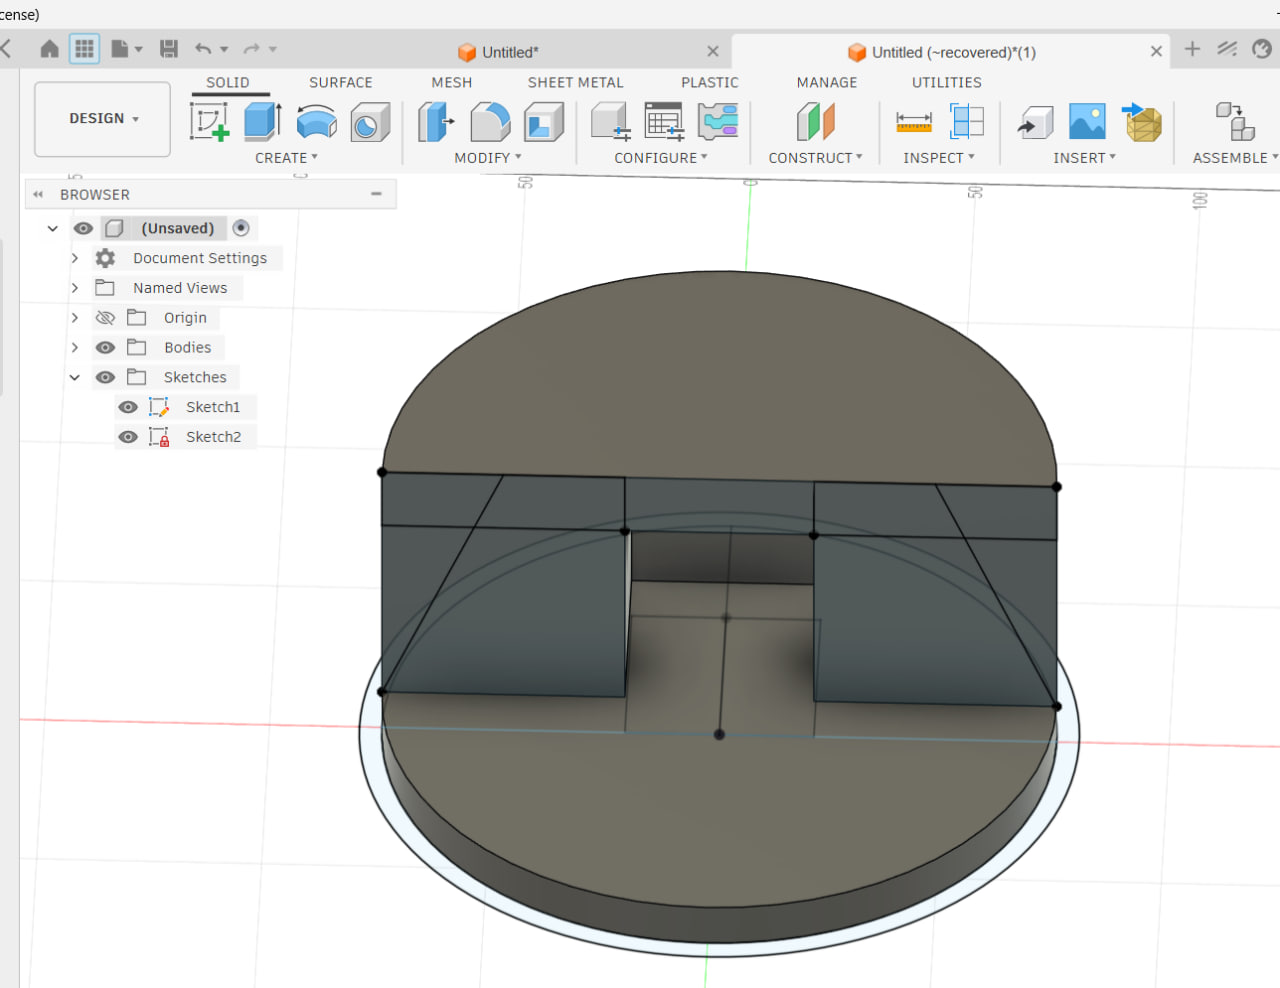
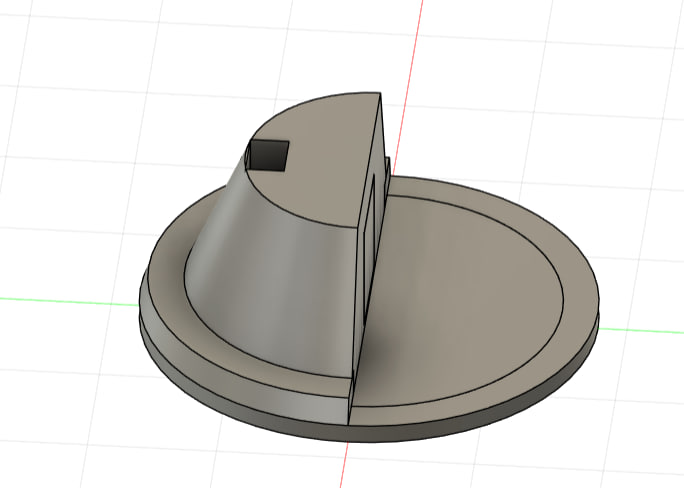
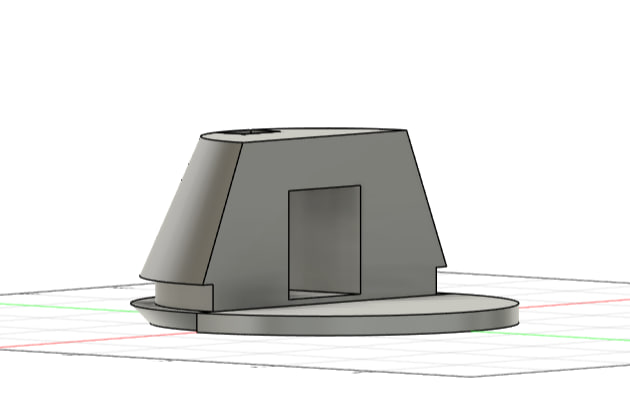
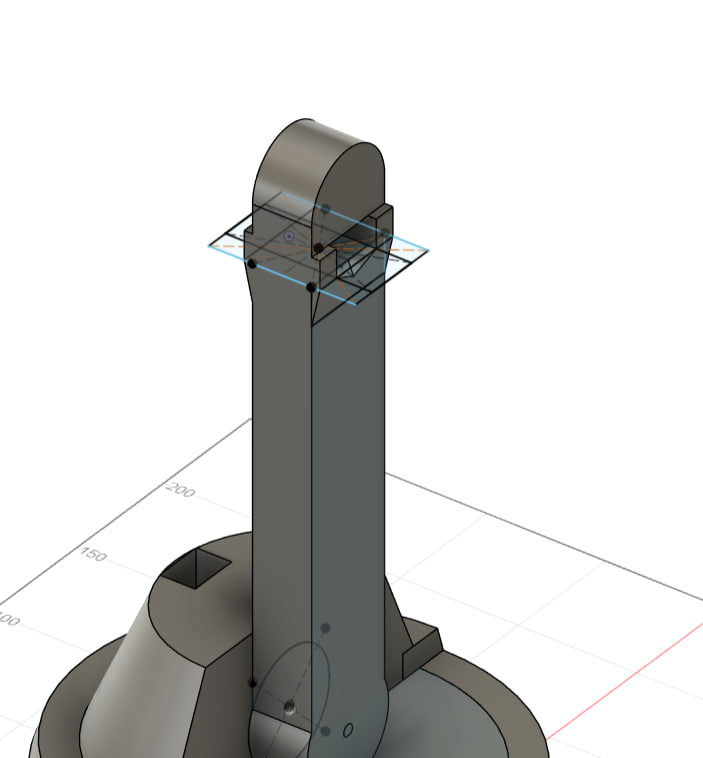
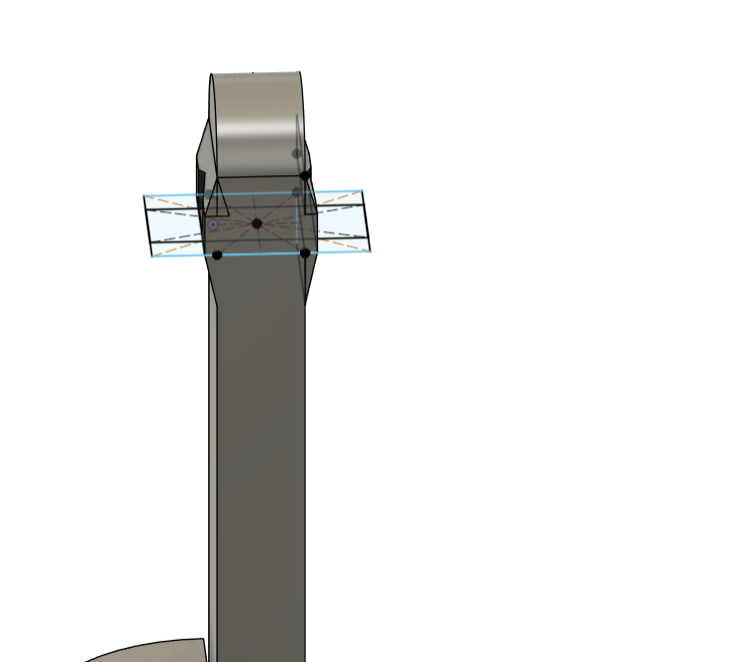
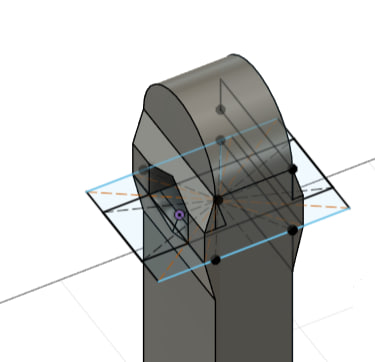
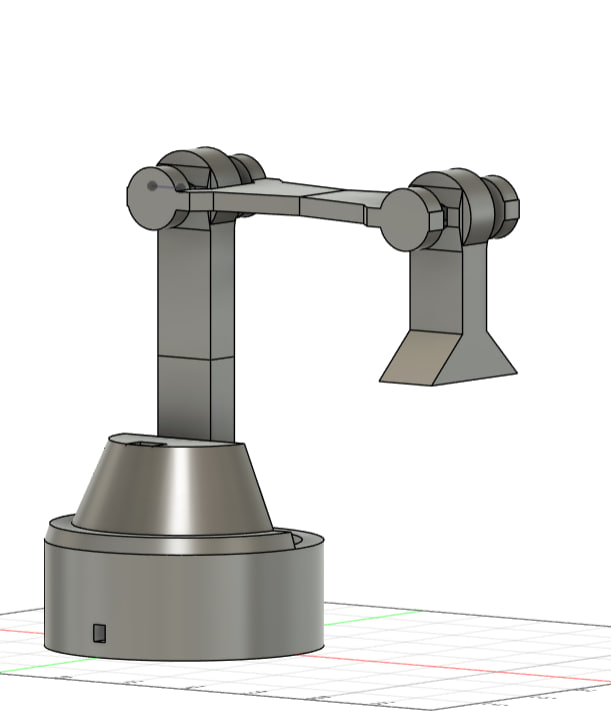
What did you design? - I am handling the mechanical parts myself along with the circuit boards and the code. The base and the turntable are in fusion 360 and it is 3d printed so it can rotate on the stepper. There are also the arm segments and the gripper with two fingers for grabbing. THere is a small case too for holding the remote. For the boards I designed two in kicad and they are single sided. One sits on the arm with the receiver microcontroller and a place for the stepper driver plus connections for the steppers and power. The other one is inside the remote and it links the joysticks and buttons to the transmitter part. The software side has two arduino programs in c plus plus. One reads where the joysticks are and sends that over esp now. The other receives the numbers and moves the steppers to match. It seems pretty straightforward but maybe there will be some issues with timing or something. I think that covers most of it.
What will it do? - My final project is a desktop robotic arm with five axes. It will pick up and move small objects like empty cups or 3D printed blocks. I am controlling it wirelessly with a separate controller that has two joysticks. The stepper motor at the bottom rotates the arm left and right while the steppers on the arm move the lower arm upper arm and wrist. The claw at the end opens and closes to grab things.
What materials and components were used? -
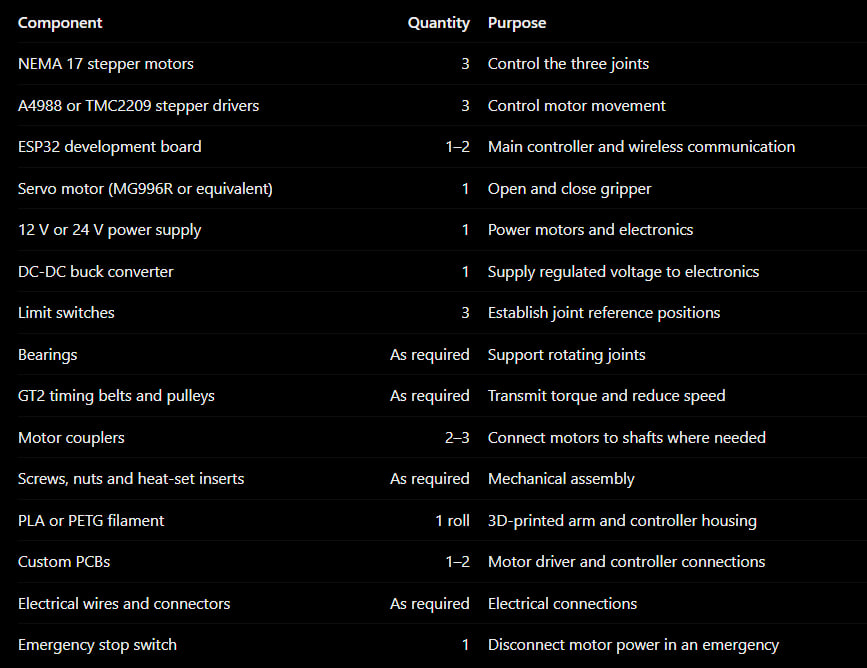 List i created with chatgpt with the prompt:
“My final project is a desktop robotic arm with five axes. It will pick up and move small objects like empty cups or 3D printed blocks. I am controlling it wirelessly with a separate controller that has two joysticks. The stepper motor at the bottom rotates the arm left and right while the steppers on the arm move the lower arm upper arm and wrist. The claw at the end opens and closes to grab things. Things i kinda know 3 stepper morors, 2 servos , 2 esp32s 3 joystics, 2 pcbs, pla for both the joystic and the robot arm case, etc”
Where did they come from? - FabLab.
How much did they cost? - Steppers cost around 10-20 euros. A stepper costs around euro and I have 6 so thats 6 euros. There will be 3-4 joystics which will cost about 4 euros. There will be 2 esp32c3 and 3 xiao-esp32 that will cost about 30 euros total. so 50-60 euros for electronics and then the cost of the material for printing is around 10 euros not more.
What parts and systems were made? There are three main parts. The web page on the ESP32. Sliders and buttons there send signals wirelessly to the mainboard. That board handles power distribution to the servos and also drives the base motor with step pulses. The physical arm uses laser cut wood along with some 3D printed pieces to keep everything in position. It seems like the electronics part is pretty central though. The servos get 5V and the stepper gets 12V through its driver. Maybe the connections could be explained more but that is how they link up.
What processes were used? - 3D printing + Lazer cutting + Vinil cutting + UV printer + PCB mill.
What questions were answered? - How to build a robotic arm using fabrication. Whether wireless control using ESP32 microcontrollers would be reliable, whether custom-designed PCBs could successfully control the motors, and whether 3D-printed parts would be strong enough for the arm to lift objects.
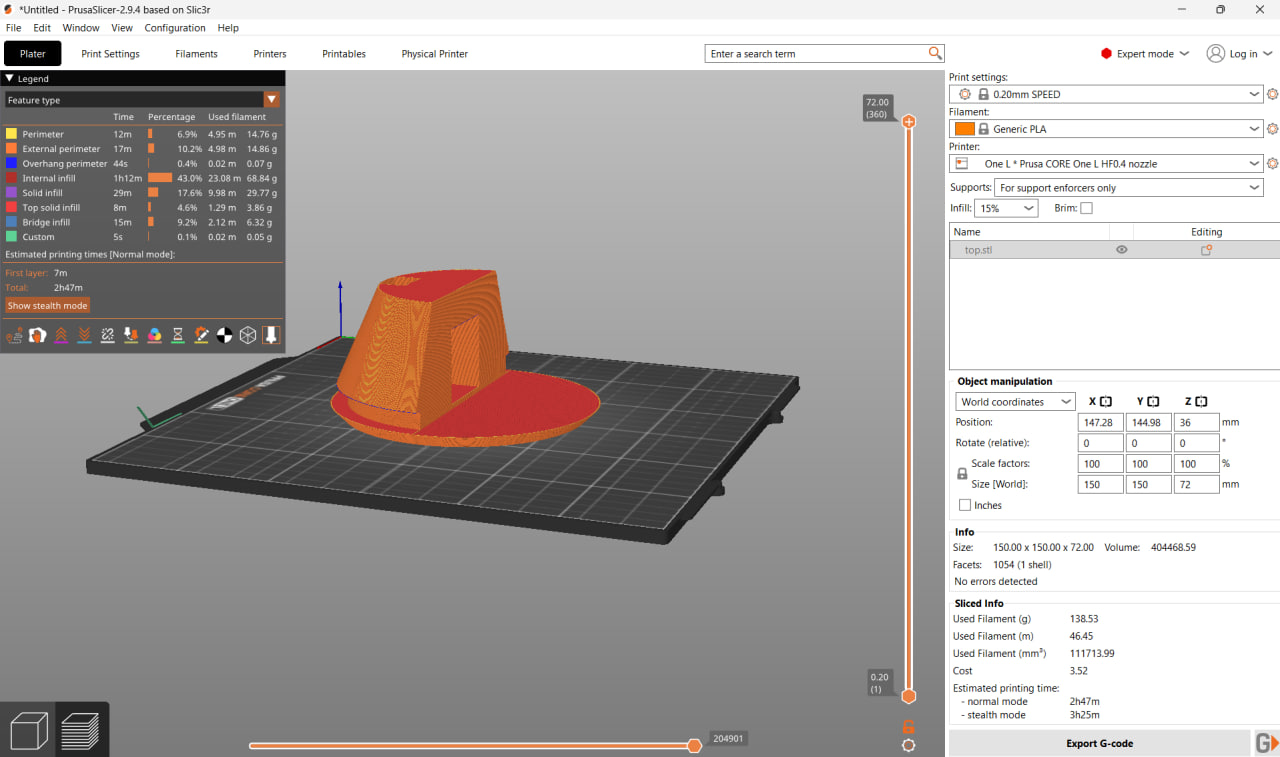
What worked? What didn’t? - Printing the whole thing takes a bit too much time so to cut down on time cutting is just a good
How was it evaluated? - It would be evaluated by testing the movement of a robotic arm, the operation of the steppers and stepper motor, wireless control trough the joystic controller and the arms ability to pick up and move objects. The results were compared against the original progect goals to verify that the system functioned as intended.
What are the implications?-The project is supposed to be a low cost robotic arm that can be designed and manufactured using 3d printing and such things. If it will move on command that will be enough.
So this is what I am doing right now.