15. System Integration
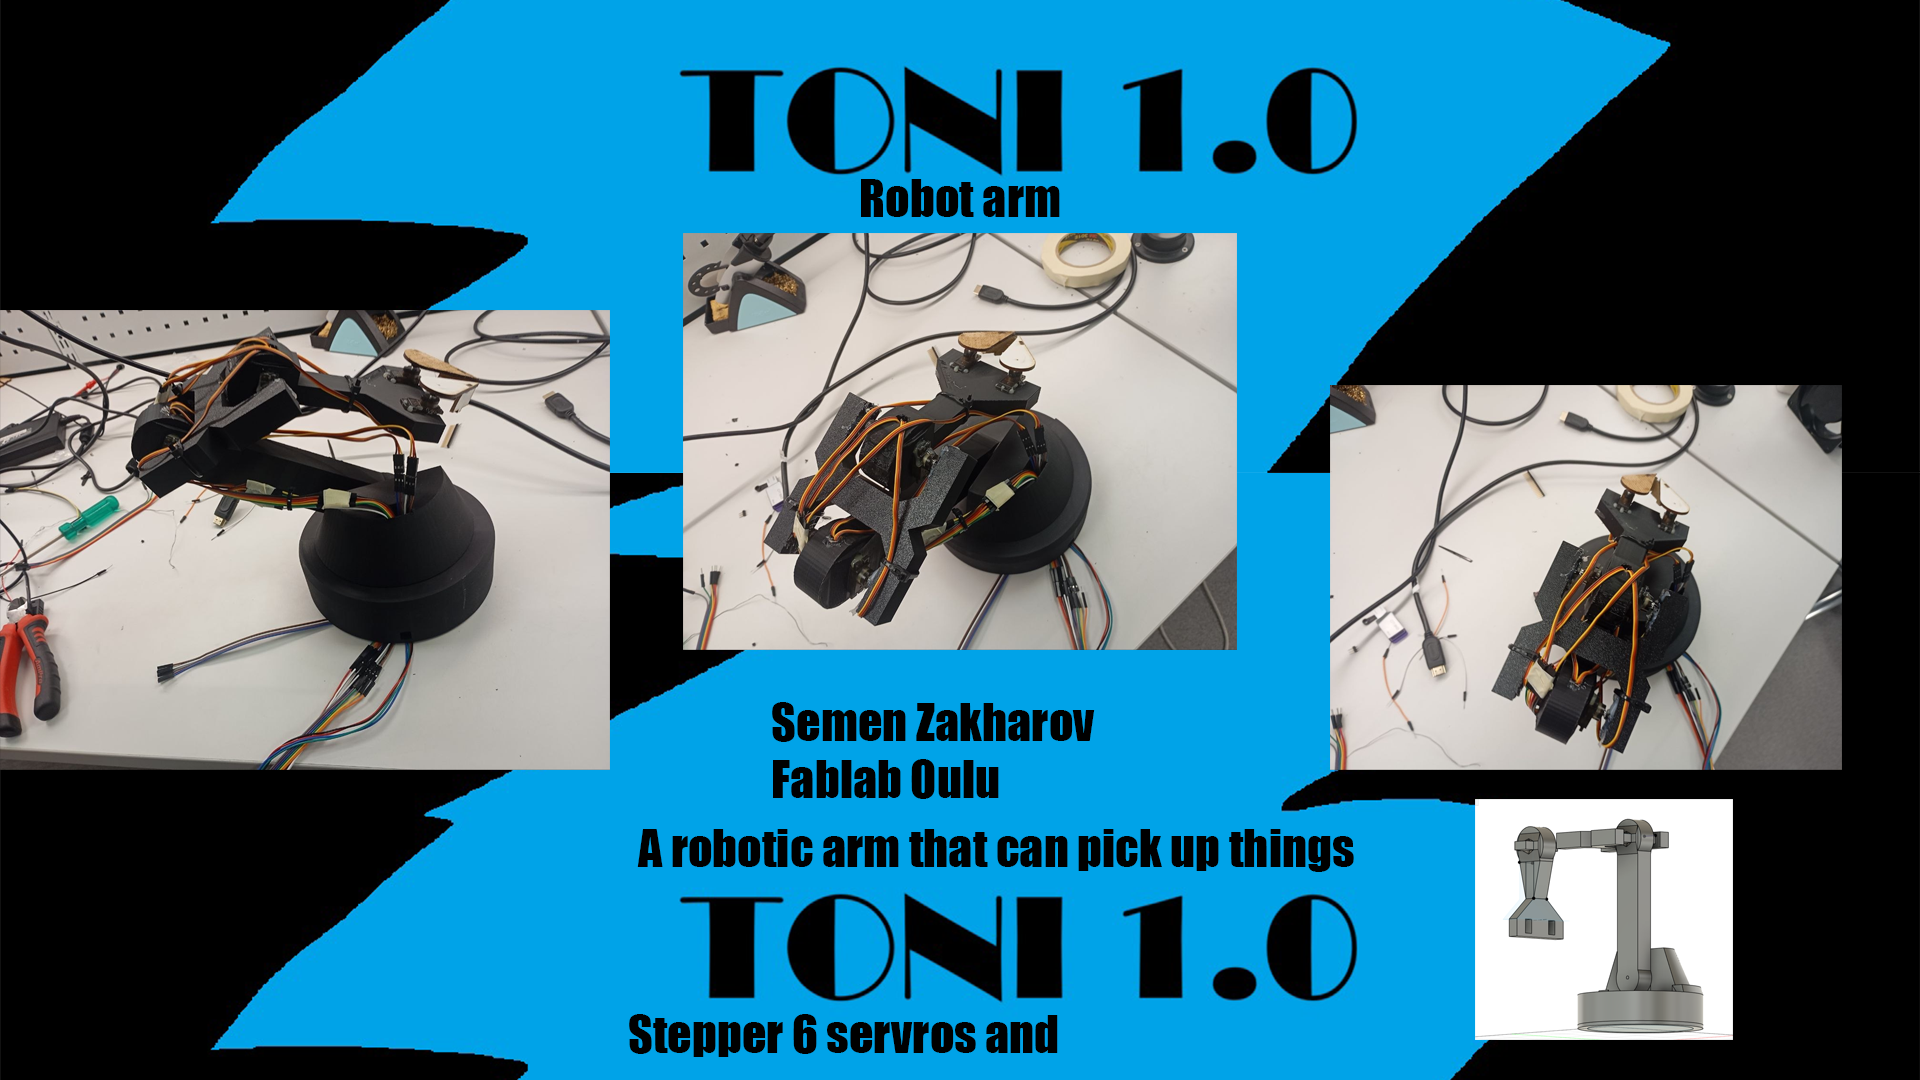 My final project is a robotic arm built using some cycloidal actuators.I want to control the arm by sending commands through a digital interface. The idea is to use a phone or web interface, with the possibility of adding a physical controller later.
I would like to bring everything i have learned(All the weeks) into one working system.
Mechanical integration
The cycloidal actuators will be integrated directly into the arm’s joints.
I will use CAD to design the arm and check that everything fits together. The design will include the actuator and the place for it , bearings, shafts and structural parts. I also plan to make an exploded view to show how the components are assembled.
Most parts will be made using 3D printing, while components that have higher mechanical loads will require better materials or manufacturing methods.
Electronics and control
A microcontroller will be as the main control. It will receive commands from a or web interface and communicate with the motor drivers, which control the motors inside the cycloidal actuators.
Thinking about how to send data, but I would like to use a wireless connection. I am also considering adding a controller as another way to operate the arm.
The general system flow will be:
Phone / Web interface → Wireless communication → Microcontroller → Motor drivers → Cycloidal actuators → Arm movement.
Packaging and wiring
The electronics will be placed in a dedicated enclosure, with proper mounting points for the controller, motor drivers and power connections.
I want to avoid loose wires around the mechanical structure, so the cables will be routed along the arm without interfering with joint movement. I will also use proper connectors to make assembly and maintenance easier.
The power supply must be able to handle the current required by the motors, especially when multiple joints move simultaneously. An accessible emergency stop will also be considered.
In the first design the wires were not thought about but I will do better in future.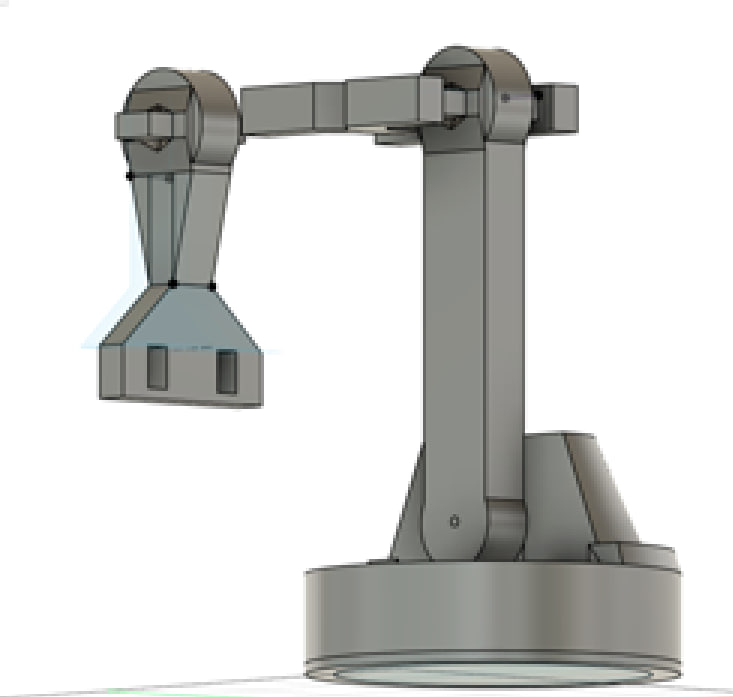
Assembly and testing
I plan to assemble and test the system gradually. First, I will finish the mechanical design and test the cycloidal actuators. Then I will connect the motors to their drivers and integrate the microcontroller.
When actuators can be controlled, I will work on the communication with the interface. And will assemble the complete arm, do the wiring and test joints working together.
I will check accuracy, stability, power consumption and communication. Any problems will be used to improve the design.
CAD and documentation
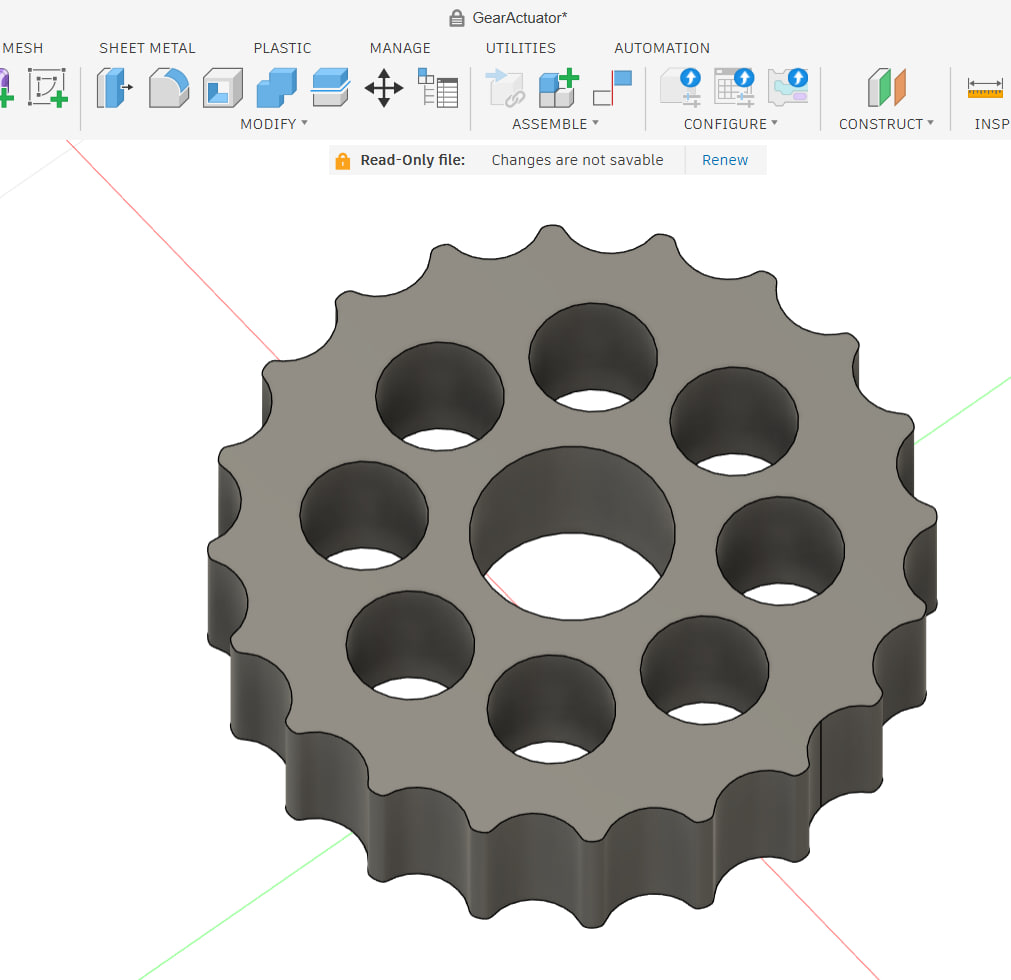
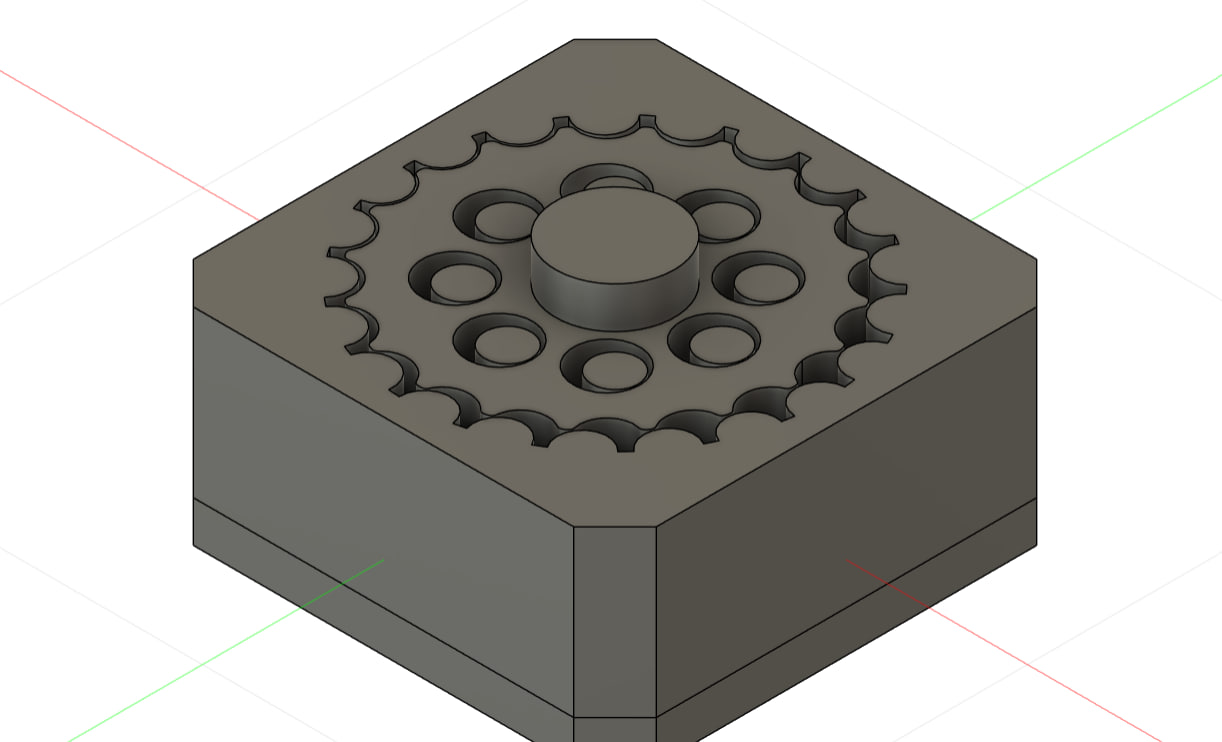
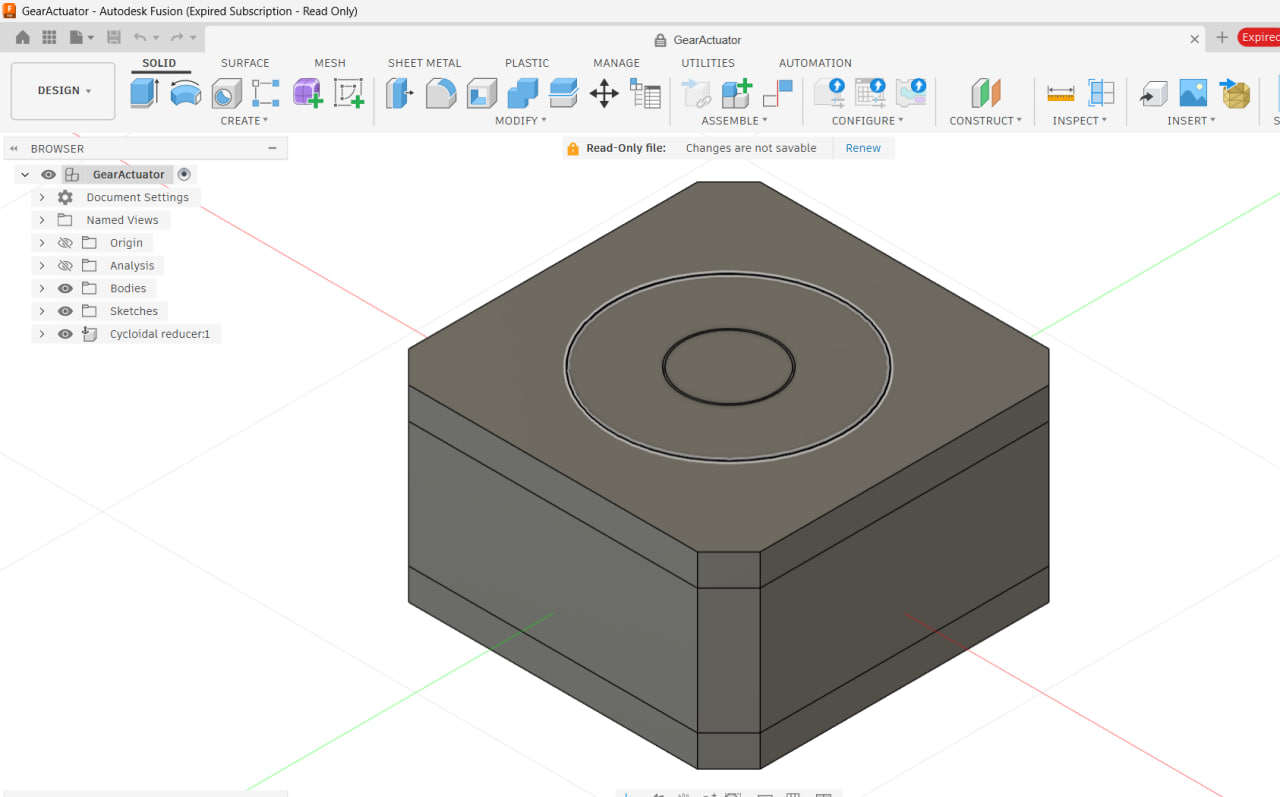
I will document the cad diagrams and photographs. The documentation will include the arm assembly, a view of a cycloidal actuator, the internal layout and a diagram showing how commands reach the motors.
I will also document the assembly process and the testing of the integrated system.
Expected result
The expected result is a remotely controlled robotic arm with cycloidal actuators that are in its joints. The mechanical and electronic components should work together quite well, with organized wiring, properly mounted electronics and a finished external appearance.
The main objective is to combine the mechanical design, electronics and programming developed during Fab Academy into one functional product.